Browse categories
Explore
Fiverr Pro
English
$
USD
Robotics Developer Digital Illustrator Technical Writer Copywriter
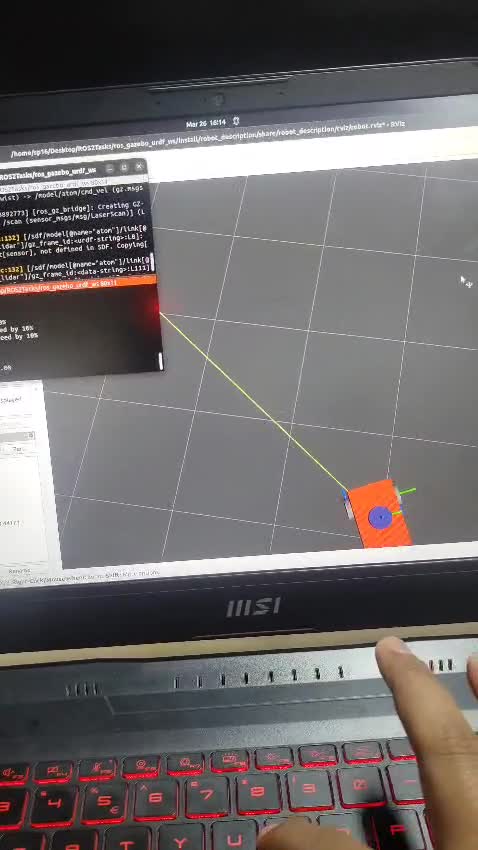
Struggling to debug ROS2 nodes, build Gazebo simulations, or write control scripts for your robotics project?
I specialize in ROS2 development, Gazebo physics simulation, and autonomous drone logic. I deliver clean, documented, and reliable software tailored to your project.
What I Offer:
Why Work With Me?
Please message me with your project details before placing an order so we can select the best package!

Platform:
NVIDIA Jetson
Sensors:
Accelerometer
•
Ultrasonic
•
Camera
•
Lidar
Q1: What information do I need to provide before starting?
Please share your OS version (e.g., Ubuntu version), ROS2 distribution (Humble, Iron, Jazzy), Gazebo version, and a clear description or script of what you want the robot/drone to do.
Q2: What if my code requires specific hardware or ROS dependencies?
I specialize in pure ROS2 and Gazebo simulation environments. If your project involves physical hardware, we can validate the control logic using simulated models first to ensure seamless integration.
Q3: Can you work with existing codebases or debug broken nodes?
Yes! I can review your existing ROS2 package or simulation environment, identify the bugs or configuration errors, and provide a fixed version along with explanations.