Browse categories
Explore
Fiverr Pro
English
$
USD

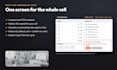


Your cell has a robot, a PLC and a pendant, but no single screen your engineers trust? I build Windows workbench software around your robot cell: live joint and TCP readback, named station I/O, simulation and gated commands that never fire without a confirm.
Portfolio: a robotics cell control platform for a six-axis cell with joint readback, named I/O with live 0/1, TCP pose, pick-cycle simulation on the bench PC, and a read-only default with confirmed writes and a session log.
What I can build for you:
Stack: C#/.NET, WPF over a robot and I/O abstraction layer.
I do not replace your robot controller or invent safety logic: sequences and interlocks are specified with you. You own the source code.
Premium / large projects: custom offer with milestone payments.
Message me your robot, controller and interface before ordering.
CAN Bus, Industrial and Robotics Desktop Software Engineer
Languages
Do you replace the robot controller or teach pendant?
No. I build software around it: readback, station screens, simulation and a gated path for the commands you approve. Motion and safety stay in your controller.
Which robots and controllers do you support?
Any controller that exposes a documented PC interface or SDK. Tell me the robot brand, controller model and interface, and I will confirm feasibility before you order.
Can we try it before the cell is free?
Yes. Simulation is part of the work and uses the same joint and I/O model as live. Final checks still happen on the real cell.
Is this ROS development?
No. This gig is a Windows desktop workbench for industrial cells. If your cell also has a ROS system, I can read data from it only through an agreed interface.


