Browse categories
English
$
USD
Connect to your AI
Drone and Robotics PCB Design Engineer for UAV Control Hardware
Your autopilot is only as useful as the sensors and peripherals it can communicate with.
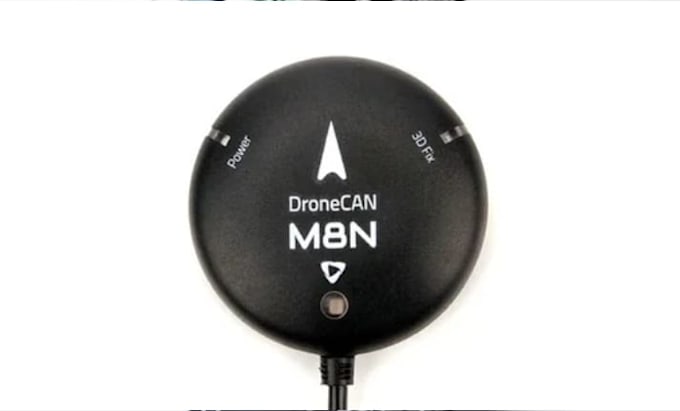
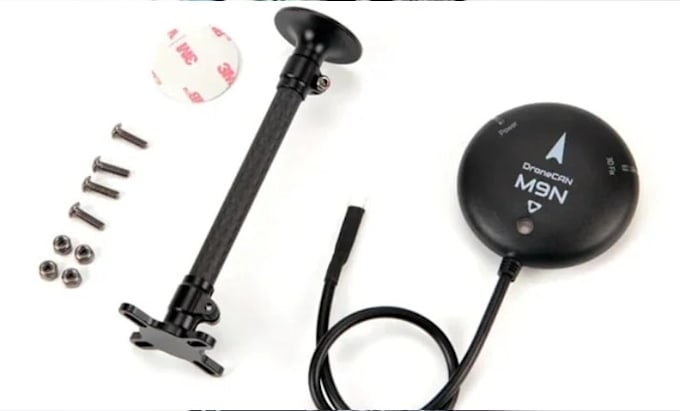
I design custom DroneCAN and UAVCAN v0 peripheral PCBs for UAV navigation, sensing, power monitoring and embedded CAN networks. Whether you need a CAN GPS module, compass interface, battery monitor or STM32 sensor node, the design starts with your flight controller and integration requirements.
HARDWARE I CAN DESIGN
DESIGN DETAILS THAT MATTER
I consider supply regulation, bus protection, connector pinout, grounding, sensor noise, PCB dimensions and manufacturing requirements. Where relevant, we can assess galvanic isolation, EMI risks and termination for your CAN network.
AUTOPILOT INTEGRATION
Design targets can include PX4, ArduPilot or supported INAV DroneCAN features. Actual compatibility depends on the selected hardware, protocol version, firmware and supported messages.
What is a DroneCAN PCB?
A DroneCAN PCB is hardware designed to connect a peripheral, such as GPS, a compass or a battery monitor, to a flight controller through a CAN network. A complete device also needs compatible firmware and protocol support.
Can you design a DroneCAN GPS and compass module?
Yes. I can design the PCB around your selected GNSS receiver, magnetometer, MCU, CAN transceiver, antenna arrangement and power requirements. Firmware and autopilot integration must be included in the agreed scope.
Do you support PX4 and ArduPilot peripherals?
I can design hardware for the intended PX4 or ArduPilot application. Compatibility depends on supported peripheral types, protocol implementation, component selection and firmware configuration.
Can you design a CAN battery monitor or power module?
Yes. The hardware can be planned around battery voltage measurement, current sensing, power regulation and a CAN interface. Current range, measurement accuracy, protection and calibration requirements must be specified.
Can you convert a UART or I2C sensor into a CAN peripheral?
I can design an adapter or STM32-based interface PCB. Translating sensor data into DroneCAN messages requires appropriate firmware and protocol support, which must be agreed separately.
Do you support isolated CAN and long cable connections?
Where required, the design can consider isolated CAN transceivers, isolated power, termination, connector protection and transient suppression. The correct solution depends on the electrical environment and network topology.
Will the PCB work immediately with my flight controller?
Not automatically. Hardware, firmware, protocol version, supported messages, node configuration and testing all affect compatibility. Please share your flight controller and target peripheral before ordering.