Browse categories
Explore
Fiverr Pro
English
$
USD
Automotive ECU PCB and Embedded Systems Engineer
Hello! Welcome to my gig. Please share your ROS2 robotics requirements, robot platform, sensors, simulation needs, or existing project files, and Ill help you develop the right solution.
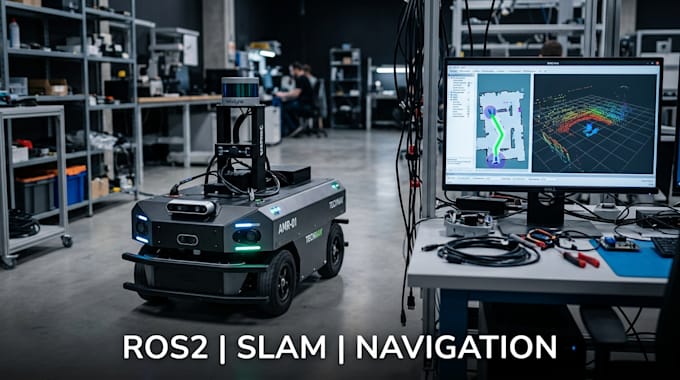
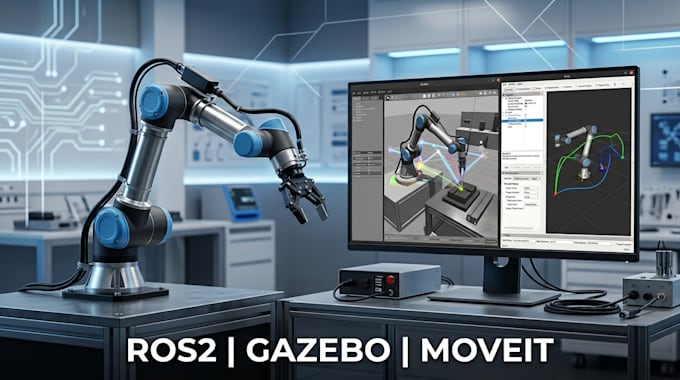
I develop custom ROS2 robotics systems, autonomous robots, SLAM, navigation, Gazebo simulation, and MoveIt solutions for mobile robots, robotic arms, and intelligent autonomous platforms.
I focus on reliable robot communication, sensor integration, mapping, localization, path planning, simulation, and hardware integration tailored to your requirements.
WHAT I OFFER
WHY CHOOSE ME
Send your robot specifications, ROS2 version, sensors, simulation requirements, existing code, or project files, and lets develop your robotics solution.
Specialization:
Circuit design
•
Schematics
•
Layout
•
Footprint
File format:
Gerber
•
STEP
•
VRML
•
BRD
•
SCH
Software:
Allegro
•
Cadence OrCAD
•
Eagle CAD
•
KiCad
•
LabVIEW
•
Matlab
Can you develop ROS2 autonomous robots?
Yes, I can develop ROS2-based autonomous robot systems with sensor integration, navigation, and control.
Can you implement SLAM and Nav2?
Yes, I can configure SLAM, mapping, localization, and Nav2 navigation for compatible robot platforms]
Do you support Gazebo simulation?
Yes, I can create and configure Gazebo simulations for ROS2 robotics projects.
Can you work with MoveIt?
Yes, I can develop MoveIt solutions for robotic arms, motion planning, and manipulation tasks.