I will debug and fix your ros2 robot navigation, tf and localization issues

Vietnam

I speak English, Vietnamese

ROS2 AMR Engineer, Nav2, SLAM, Real Robot Deployment

I build and fix ROS2 software for real mobile robots, not just simulations. For 8+ years I led an AMR team, taking robots from early prototypes to production, including a fleet of 20+ AMRs deployed in...
About this Gig

Robot drifting, losing localization, TF errors, or Nav2 behaving strangely? I will find the root cause and fix it.


I lead an AMR team and have spent years keeping production robots running, including 20+ AMRs at a FedEx facility in Japan. Most problems I see come from a few places: TF trees, timestamps, odometry, sensor configs and tuning.


Common issues I fix:

  • TF errors: missing or wrong transforms, extrapolation, timing
  • Odometry and IMU drift, bad wheel parameters
  • AMCL or SLAM losing localization
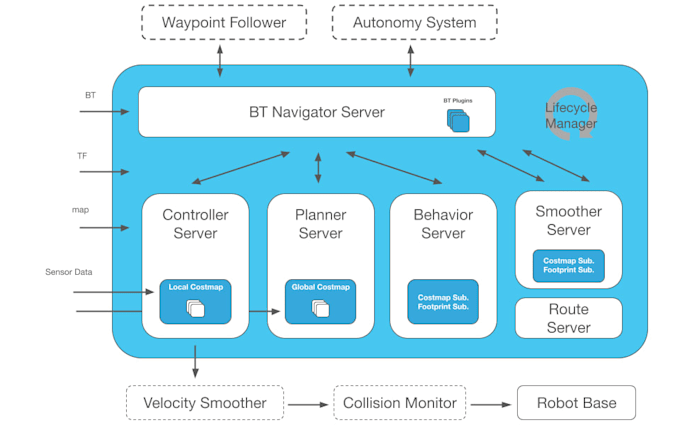
  • Nav2 oscillating, getting stuck or ignoring obstacles
  • Lifecycle, launch and parameter problems
  • Missing diagnostics, health checks or safety stops

How it works:

  • You share your code, a rosbag and a short description of the problem
  • I reproduce, find the root cause and explain it clearly
  • I fix it (Standard/Premium) and document what changed

Please message me before ordering with a short description of the issue so I can confirm I can help.
Platform:

Raspberry Pi

Sensors:

Ultrasonic

•

Infrared

•

Camera

•

Lidar

Expertise:

Debugging

•

ROS

•

Programming

•

Robotics