Browse categories
English
$
USD
Connect to your AI
Robotics and Embedded Systems Engineer, ROS 2, Computer Vision, Sensor Fusion
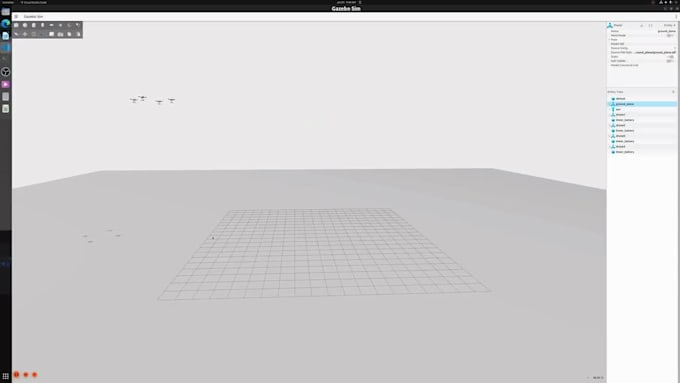
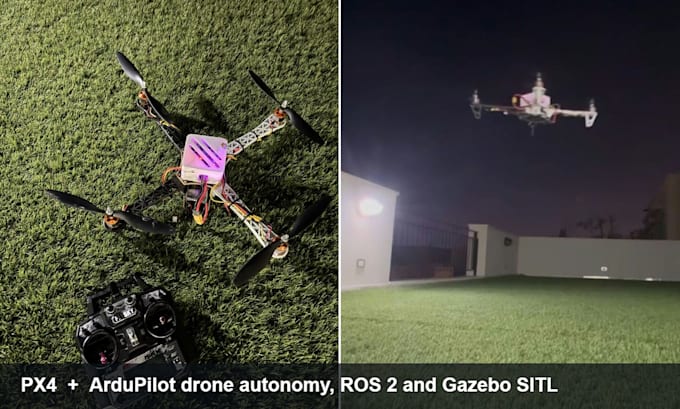
Need your drone to fly a mission on its own, follow a target, or run your code onboard? I build and debug PX4 and ArduPilot autonomy, and I test it in simulation before it touches your airframe.
What I can do:
Relevant work:
Please message me before ordering with your autopilot, airframe and what the drone should do, so I can confirm the right package.

Platform:
Raspberry Pi
Expertise:
Firmware development
•
ROS
•
Robotics
Do you work on real drones or only in simulation?
Both. I develop and test in SITL first so nothing risky reaches your aircraft, then I support your flight tests remotely through flight logs, video calls and parameter changes.
PX4 or ArduPilot, which one do you work with?
Both. If you have not picked one yet, I will recommend one based on your airframe, payload and mission, and explain the trade-offs before we start.
What do you need from me to start?
Your autopilot and firmware version, airframe type, companion computer if you have one, and a short description of the mission. Flight logs (.ulg or .bin) and videos help a lot when debugging.