Browse categories
Explore
Fiverr Pro
English
$
USD
I build the perception, mapping, and navigation software that lets autonomous vehicles and mobile robots understand and move through the real world.
What I deliver:
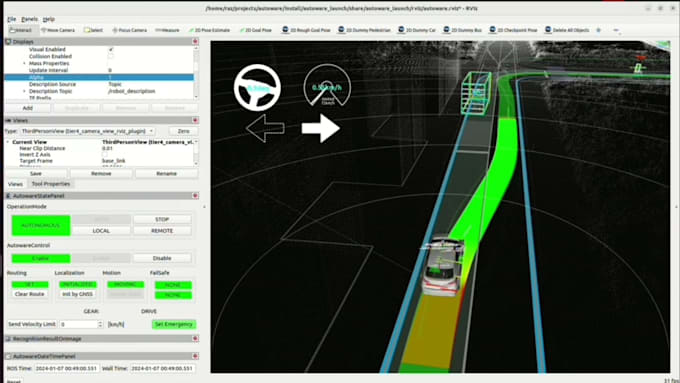
- Autonomous vehicle software: perception, localization, path planning, control
- 3D mapping and SLAM using LiDAR, depth cameras and point-cloud data
- F1TENTH-scale autonomous racing: high-speed navigation, obstacle avoidance, real-time decisions
- Mobile robot (AMR) navigation for indoor and outdoor environments
- Sensor integration: LiDAR, depth cameras, IMU and wheel odometry
My background: I founded SUST Autodrive, building a two-seater EV that logged 500+ km of real-world testing, and I built the full perception-to-control stack for an F1TENTH-scale autonomous racing car. My team was a semifinalist (top 22 of 153 international teams) at the Bosch Future Mobility Challenge 2026, where I worked on vehicle connectivity algorithms. I have also built an indoor autonomous mobile robot using LiDAR and depth-camera localization, and a teleoperated rover with LiDAR/depth-camera mapping.
Send me your robot or vehicle setup and your goals, and I will tell you exactly what is needed to get it navigating reliably.


| (1) | ||
| (0) | ||
| (0) | ||
| (0) | ||
| (0) |
musis96

Turkey
thank you for everything.
$50
Price
7 days
Duration
| (1) | ||
| (0) | ||
| (0) | ||
| (0) | ||
| (0) |
musis96
Turkey
thank you for everything.
$50
Price
7 days
Duration