Browse categories
English
$
USD
Connect to your AI
Robotics, Computer Vision, PCB, and Embedded Systems solutions
Hi there! I'm Shehab Abdo, a robotics engineer with experience in ROS (Robot Operating System). Whether you need a quick consult, a custom driver, or a complete autonomous solution, I'm here to help you bring your robot to life.
What I Offer:
ROS Consultation Architecture review, performance tuning, best practices.
Custom Nodes & Drivers Sensor interfaces, motor controllers, message filters.
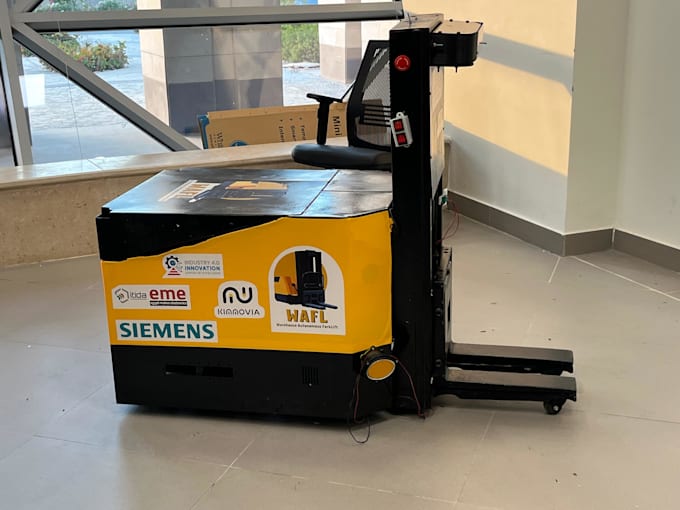
Navigation & Autonomy SLAM, localization (AMCL), path planning (NavFn, DWA), waypoint following.
Simulation & Visualization Gazebo world setups, RViz configs.
Deployment & Training
How Well Work Together:
Kickoff & Requirements You share your project goals, hardware specs, and timeline.
Implementation I develop in iterative sprints with regular checkpoints.
Delivery & Support You receive tested packages, launch files, and setup guide, plus one week of free Q&A.


Control type:
Mobile Robots (AGVs)
Device brands:
Universal Robots
Programming language:
C/C++
•
Python
Software:
Other
Can you work with ROS1 and ROS2?
Yes. Please specify your ROS distribution and Ubuntu version before ordering.
Can you integrate LiDAR and camera sensors?
Yes. I can help integrate supported sensors and process their data within a robotics software architecture.
Can you develop autonomous navigation systems?
Yes. I can work on mapping, localization, navigation, and path-planning components, depending on your robot and project requirements.
Do you provide hardware and physical robot assembly?
The standard packages focus on software, algorithms, integration, and documentation. Hardware procurement and physical assembly require a separate agreement.
Can you work on a complete autonomous mobile robot?
Yes, but complete robotics systems require a custom scope, milestones, timeline, and quotation.
What do you need before starting?
I need your project description, hardware details, software environment, required functionality, and expected deliverables.