Browse categories
English
$
USD
Connect to your AI


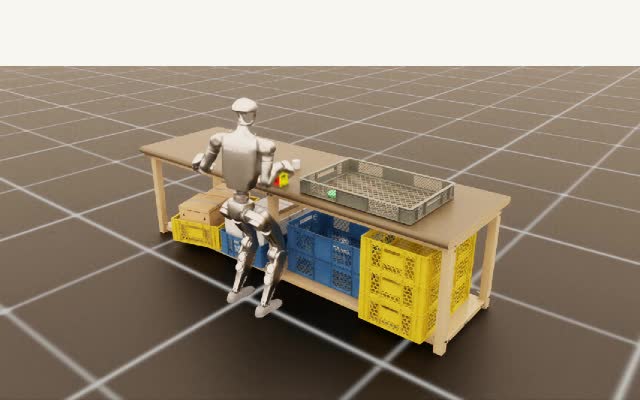
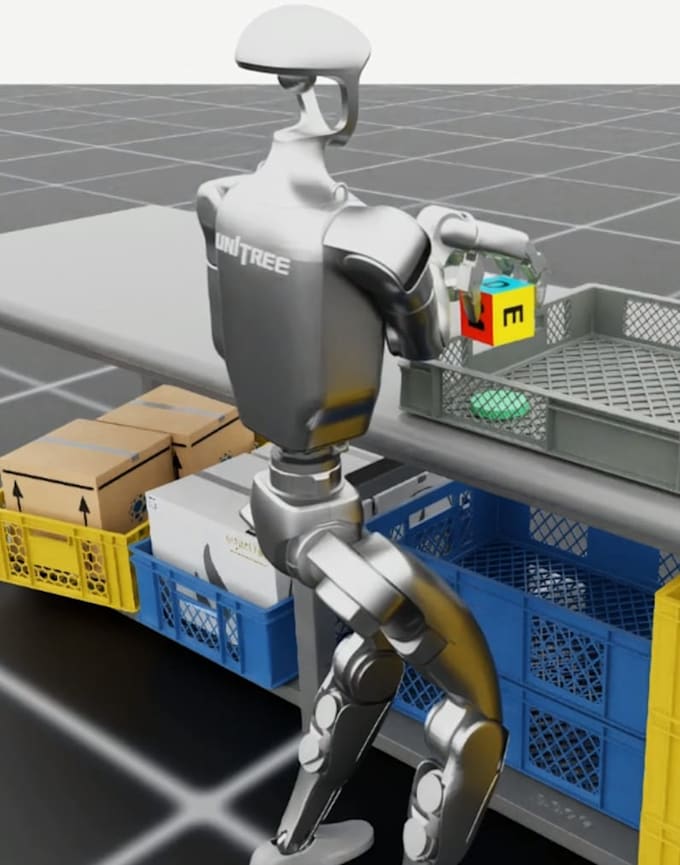
We build custom embodied AI simulation and synthetic trajectory datasets on NVIDIA Isaac Sim for humanoid robots and dexterous hands. We design custom simulation scenes, import and configure URDF/USD robot assets, set up sensors, apply domain randomization, inject sensor noise, tune IK, WBC and MPC controllers, and export LeRobot-compatible HDF5 trajectory data for imitation learning and reinforcement learning research.
Our Basic and Standard packages deliver datasets for a single scene and one data type. The Premium tier supports full development of an end-to-end self-running synthetic data generation platform.
The listed prices correspond to single-scene, single-data-type orders. Additional pricing for multiple data types in one scene, or the custom platform project under Premium, will be negotiated separately after reviewing your requirements.
Simulation Platform Development Specialist
Languages