Browse categories
Explore
Fiverr Pro
English
$
USD

Python Automation Developer
Skills
See my services

Independent Python Developer
Self-Employed / Freelancer • Freelance
Aug 2026 - Present • 3 mos
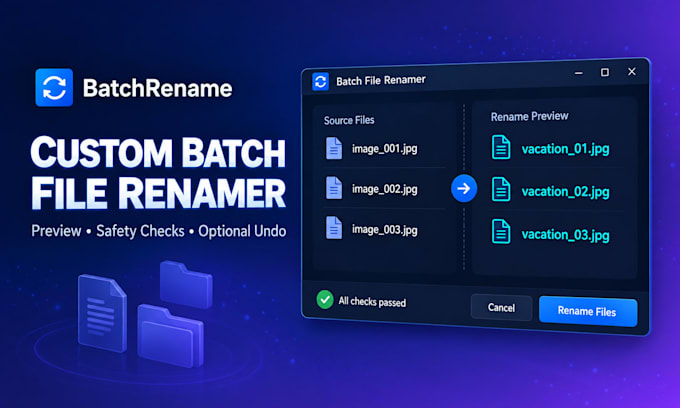
Developed practical Python desktop tools for data and file-processing tasks, including Excel and CSV cleaning and comparison, batch file renaming, PDF merging and page extraction, image resizing and format conversion, and QR code generation. Built user-friendly interfaces with Tkinter and added input validation, error handling, preview functions, and safe output management. Focused on reliable operation, readable code, and clear documentation.

Intern Programmer
Baidu • Part-time
Jun 2021 - Aug 2021 • 2 mos
Responsible for the development and debugging of core control algorithms for the painting robot, gaining a deep understanding of its working principles and motion control logic. Precisely controlled the robot's vertical movement speed by adjusting stepper motor parameters, significantly improving operational stability and efficiency. Optimized servo control logic to resolve issues with the spray gun's rotation, enhancing the uniformity and smoothness of the coating. Developed data acquisition algorithms for planar LiDAR, enabling real-time environmental perception and obstacle avoidance during construction.
