Browse categories
English
$
USD
Connect to your AI
Drone, PCB, Embedded Firmware and ROS 2 Robotics Engineer
Level 1
Has met certain performance criteria and shows strong potential in the marketplace.
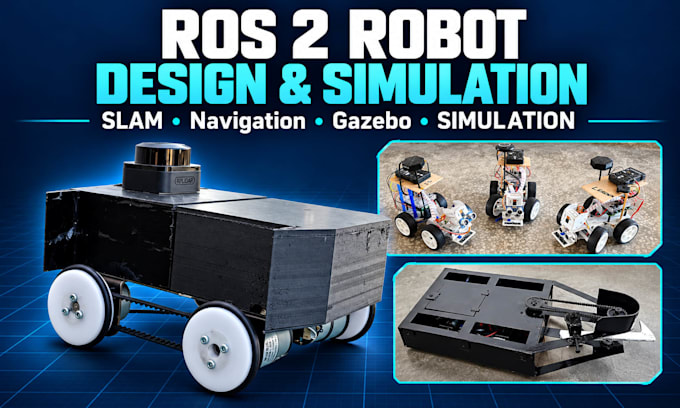
Is your robot driving but not mapping or navigating? I develop ROS 2 software so your mobile robot can build a map with SLAM, localize itself and navigate to goals with Nav2, tested in Gazebo simulation and on real hardware.
What I set up
- ROS 2 workspace, URDF/Xacro robot model and TF tree
- Lidar, wheel encoder and IMU drivers with odometry fusion (robot_localization)
- SLAM mapping with slam_toolbox, map saving and editing
- Nav2: AMCL, costmaps, planners, controller tuning and waypoints
- Gazebo simulation world and RViz views
- Camera and YOLO object detection on request
Built and tested by me: a ROS 2 robot with Raspberry Pi 4, RPLidar C1, encoder motors and Nav2 that maps unknown rooms, and a leader-follower robot swarm using Raspberry Pi, Pixhawk, MAVLink, MQTT and YOLOv5.
How hardware work runs: I develop in Gazebo and on my own lidar robot, then guide you on your robot over a live screen share. Robot hardware is not included.
Send your robot, ROS 2 version, sensors and goal before ordering.

Q1. Which ROS 2 versions do you support?
Tell me your ROS 2 distribution and Ubuntu version before ordering. I set up packages for that version and confirm your lidar driver works first.
Q2. Do I need a physical robot?
No. Standard and Premium include a Gazebo simulation. If you have a robot, I guide you to run the same setup on it in a live session.
Q3. Which lidars and computers do you support?
Any lidar with a working ROS 2 driver. I have built with an RPLidar C1 on a Raspberry Pi 4. Jetson and PC setups are confirmed per order.
Q4. Do you build the robot hardware?
Not in this gig. I configure software for your robot. Motor drivers, wiring or a custom PCB can be ordered through my firmware or PCB gigs.
Q5. Can you add a camera or object detection?
Yes, with the Object Detection extra. I have used YOLOv5 on Raspberry Pi robots; scope depends on your model and hardware.